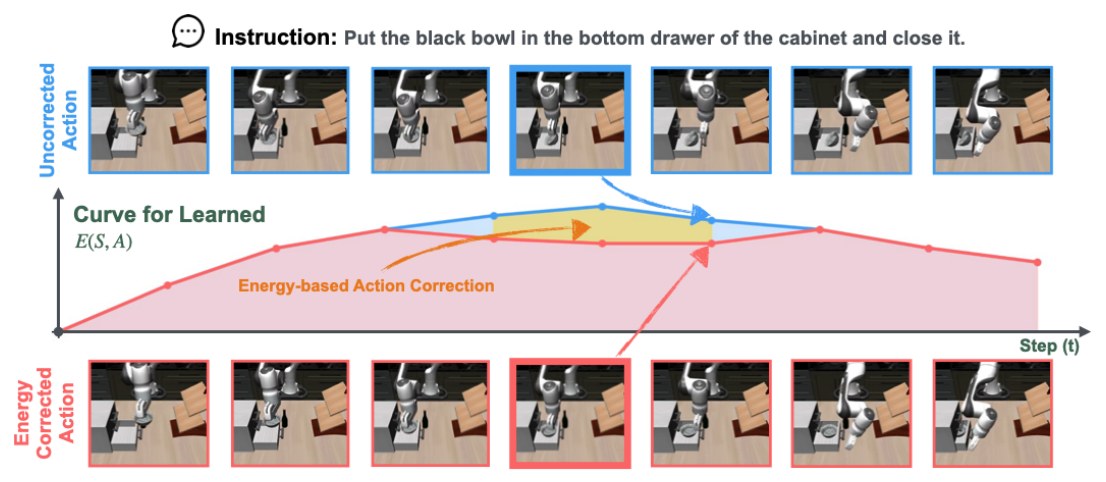
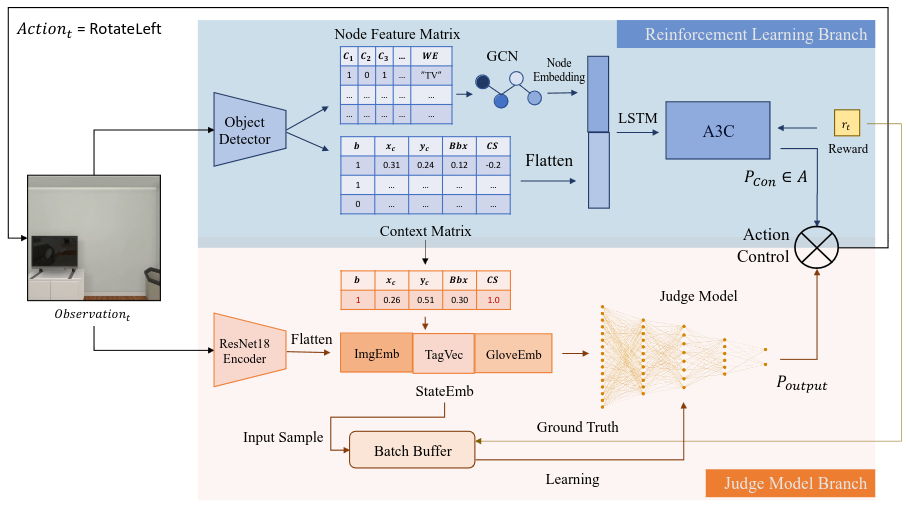
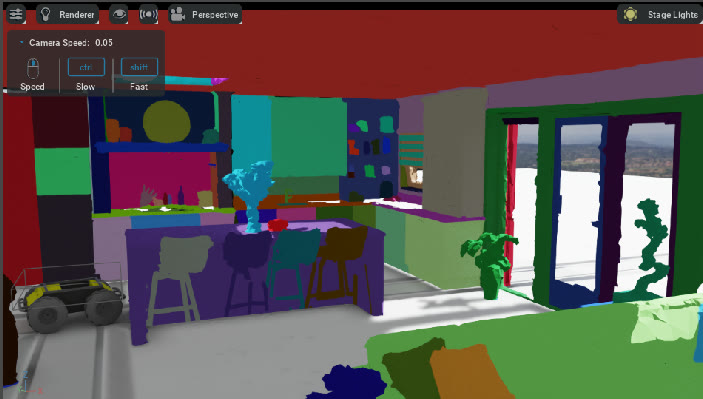
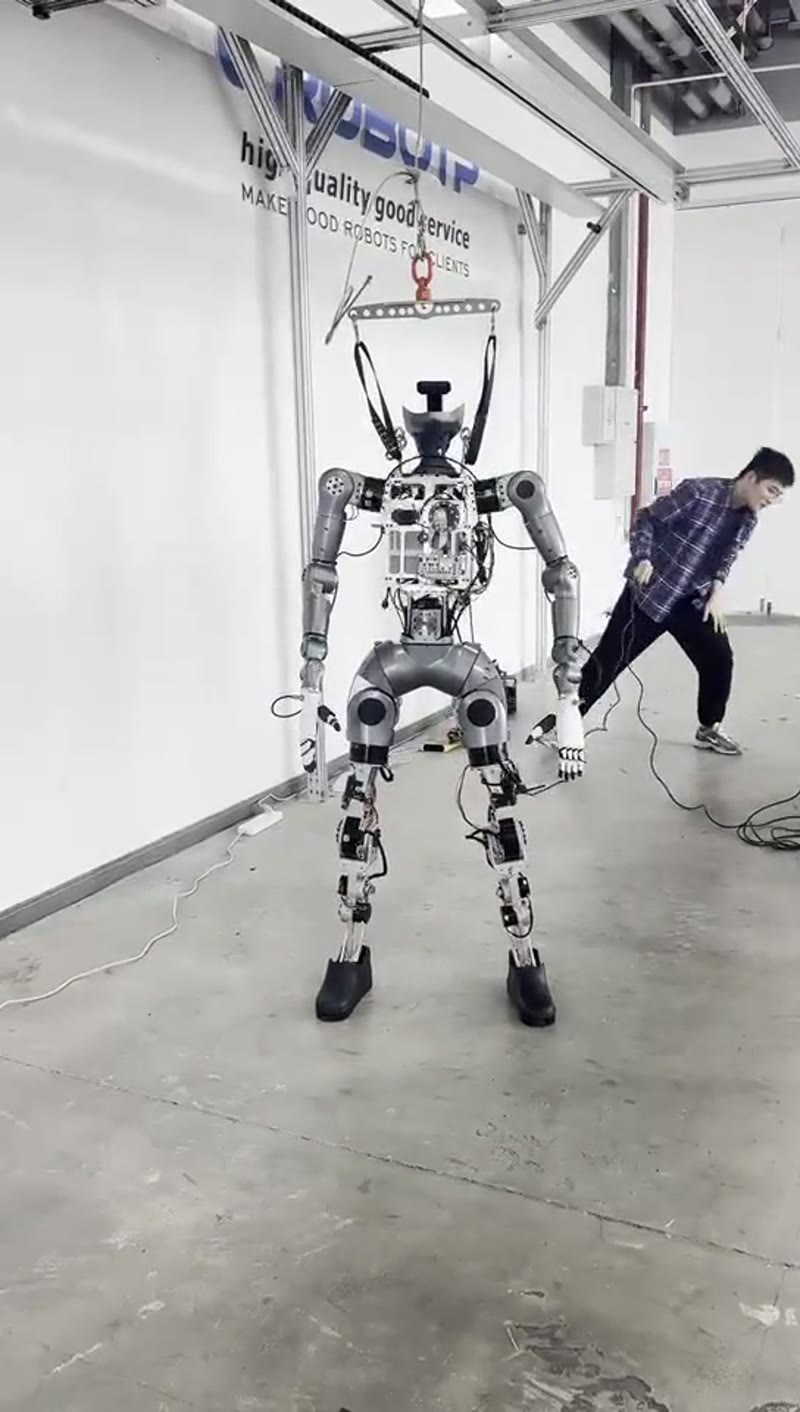
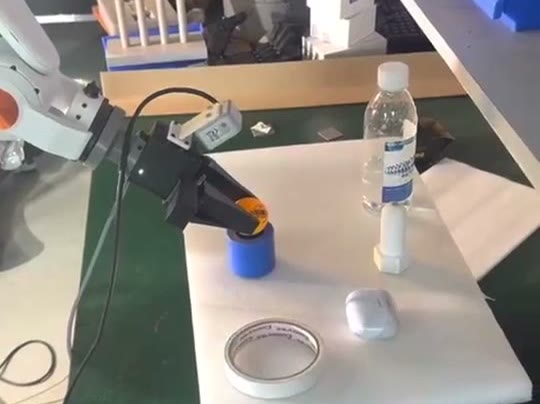
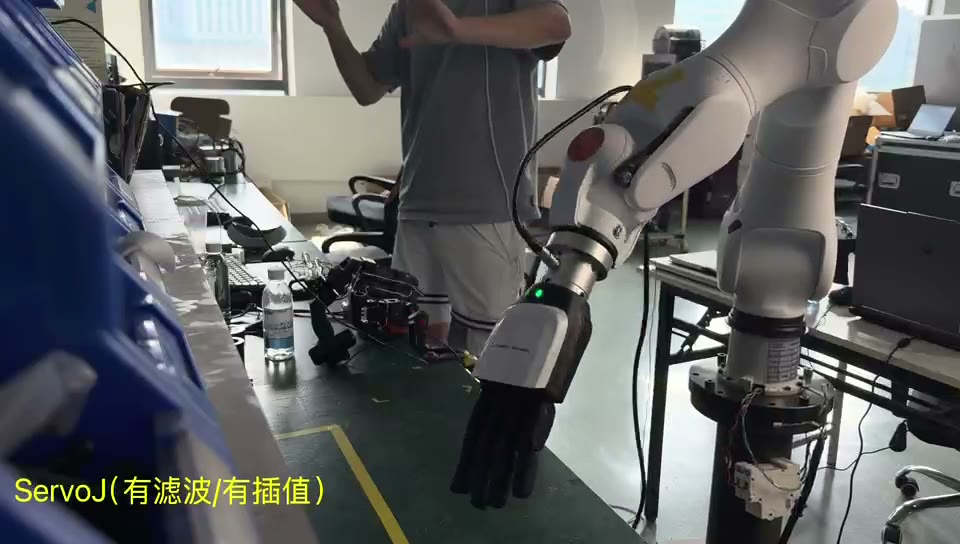
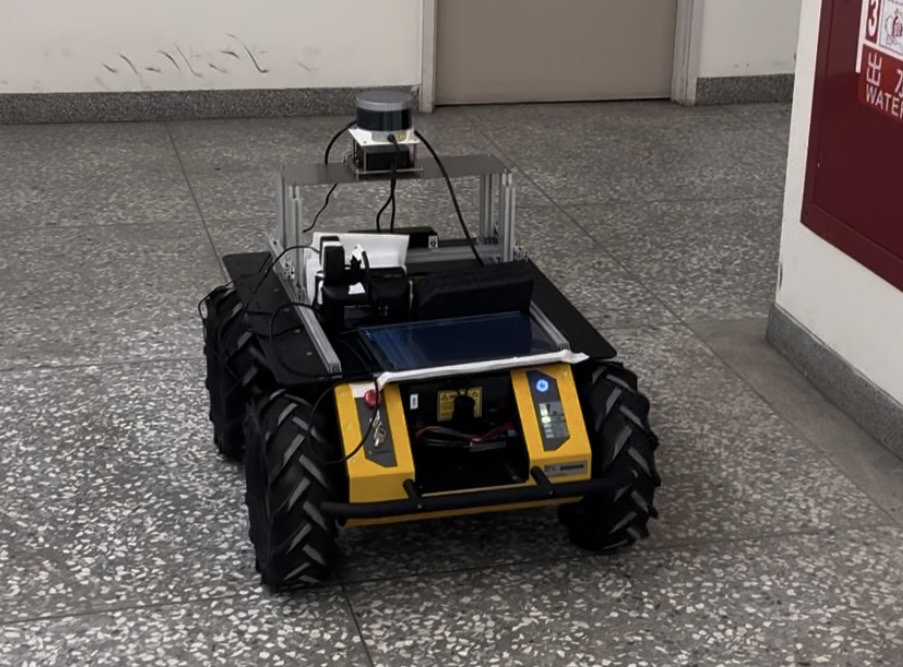
Research VEL: Vision-Grounded Energy Critics Vision-grounded energy critics for physically feasible vision-language-action policies. A compact energy head corrects each action of a frozen VLA with one gradient step, with no rollouts or retraining. DITA Agent Depth-Inference Termination Agent for object navigation in AI2-THOR. A judge model trained alongside reinforcement learning decides when the agent has reached its target. Real-World Aligned Embodied Navigation An object-goal navigation system that trains a CLIP-guided reinforcement learning agent on HM3D homes in NVIDIA Isaac Sim, with a ROS2 Humble mapping stack shared with the real Husky robot. Industrial Supermimic on CRP Humanoid Taking our in-house humanoid crp from dancing in simulation to walking on a gamepad and playing motions at the press of a button, with world-model policy learning from SuperMimic. RoboJev Testing the new generation of decision models (Jev, Laya, PlayJev and the OpenAI Decisions API) as the brain of a robot arm for the atomic action of grasping. Dexhand AR Teleoperation Apple Vision Pro teleoperation of a 7-DoF Rokae AR5 arm and an Inspire dexterous hand, with closed-form redundant IK and servoJ streaming at 8 ms. Prophet System AI online prediction platform. Husky Road-Marking Robot LiDAR-guided wall following with PID control for autonomous highway line drawing, developed in NVIDIA Isaac Sim and deployed on a real Husky UGV with ROS1.