VEL: Vision-Grounded Energy Critics
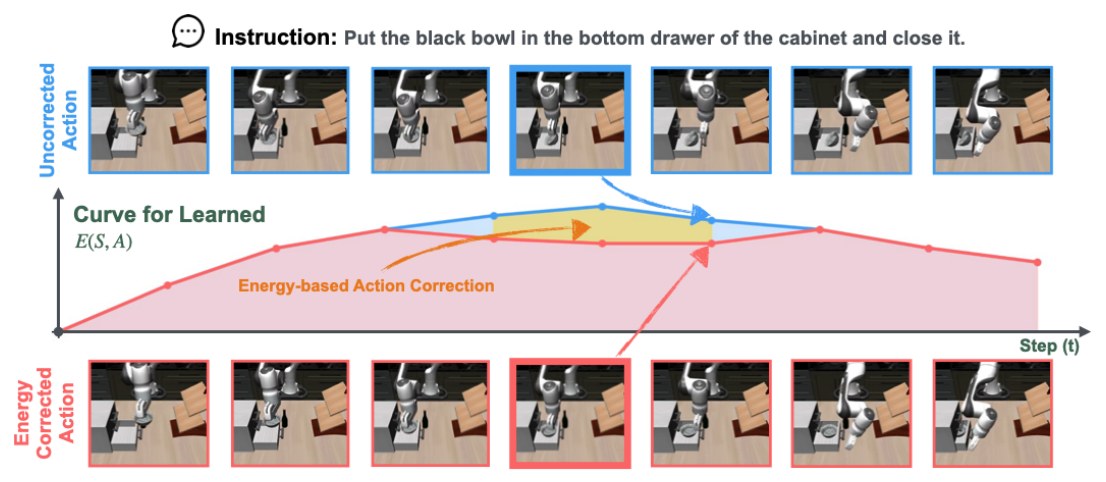
Vision-grounded energy critics for physically feasible vision-language-action policies. A compact energy head corrects each action of a frozen VLA with one gradient step, with no rollouts or retraining.
山海亦可平 · Building intelligent agents that can read the world and move through it.
I am a Ph.D. student at the University of Liverpool and National Tsing Hua University, working at the intersection of embodied intelligence, deep learning, and autonomous systems.
My research life moves between airvLab at the Digital Innovation Facility and ELSA Lab at NTHU. I founded TOPSOFT Group in 2016 as an international organization for computer science.
I am interested in agents that can perceive, decide, and act with efficiency in the physical world. The long-term aim is to build robust end-to-end navigation systems that feel less like isolated models and more like reliable companions for real environments.
| Apr 1, 2026 |
Two papers accepted to ICPR 2026 ! |
|---|---|
| Jul 14, 2025 | Started AMD full-time internship in Shanghai! Focusing on Embodied AI with rocm. |
| Oct 12, 2023 | I serverd as external reviewer at ICLR 2023. |
| Sep 11, 2023 |
One paper is accepted to ACML 2023 ! |
| Aug 14, 2023 | Building Real World Aligned Embodied Autonomous Navigation System! <3 |
| Jun 20, 2023 | Started my journey on learning ROS 1 & 2, preparing working on embodied Husky robots. |
| Jan 18, 2023 | I serve as module demonstrator for COM 341 in UoL. |
| Oct 1, 2022 | Learning on RL basics and Efficient Models. |
| Jul 19, 2022 | I got an fully-funded PhD offer from University of LIverpool. |
| Jun 18, 2022 |
Received my Bachelor degree from University of Liverpool. |
Vision-grounded energy critics for physically feasible vision-language-action policies. A compact energy head corrects each action of a frozen VLA with one gradient step, with no rollouts or retraining.
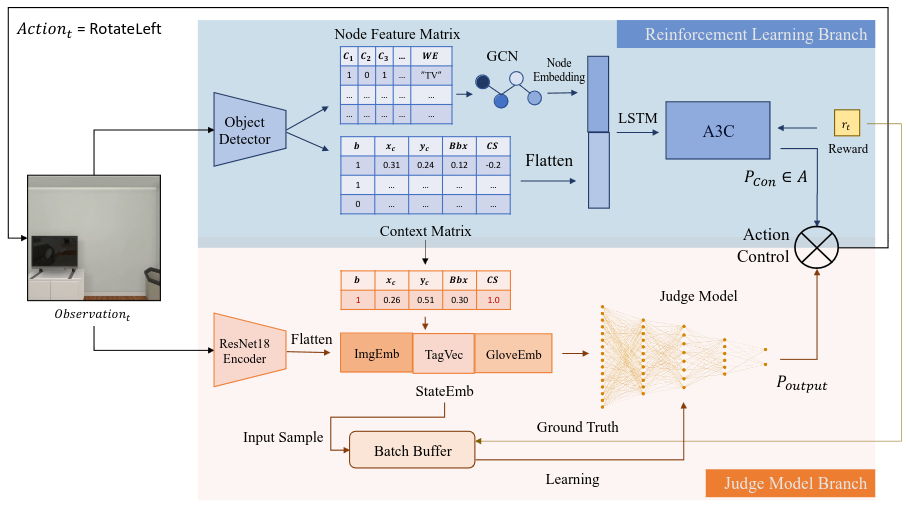
An novel approach to object navigation in AI2-THOR. Code and resources, visualization are available here.
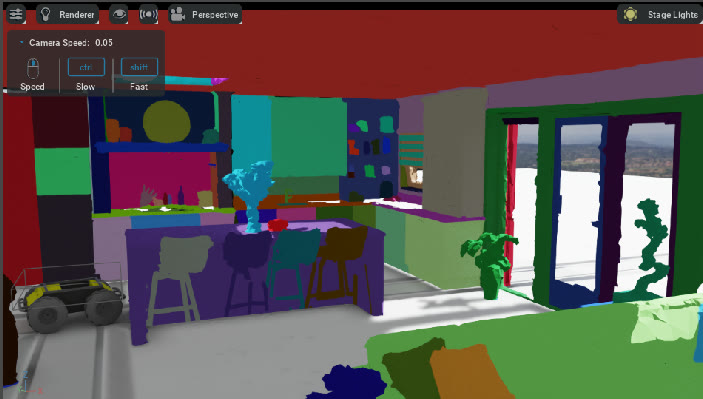
An object-goal navigation system that trains a CLIP-guided reinforcement learning agent on HM3D homes in NVIDIA Isaac Sim, with a ROS2 Humble mapping stack shared with the real Husky robot.
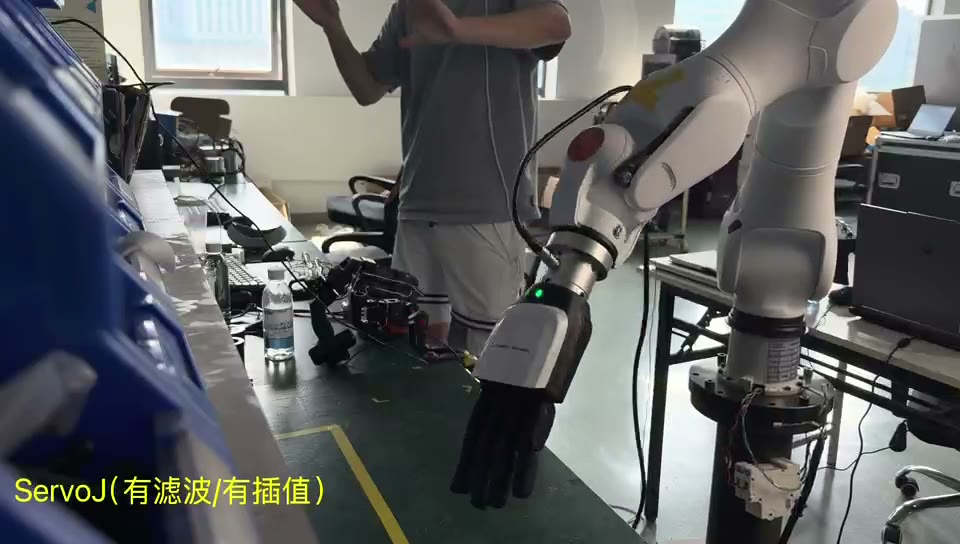
Apple Vision Pro teleoperation of a 7-DoF Rokae AR5 arm and an Inspire dexterous hand, with closed-form redundant IK and servoJ streaming at 8 ms.
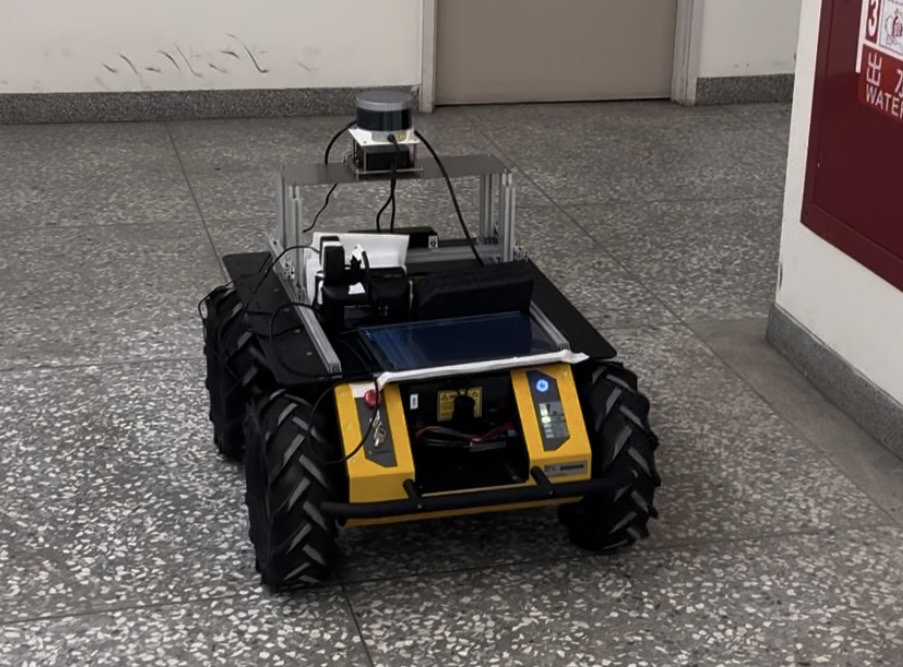
LiDAR-guided wall following with PID control for autonomous highway line drawing, developed in NVIDIA Isaac Sim and deployed on a real Husky UGV with ROS1.
Explore the full archive of work and writing.